DA0T1 High-Speed Seeker for Fast UAV Tracking
Gimbal Pod · Product guide
The DA0T1 high-speed seeker is a compact electro-optical payload for UAV and other high-speed airborne platforms. It combines 1280×720 monochrome imaging at 120 fps with 6T onboard AI for detecting and tracking people, vehicles, and drones. Its two-axis servo gimbal, 180 g maximum weight, and Ethernet and serial interfaces support integration where rapid visual observation and target tracking are priorities.
Verified specifications
| Sensor and resolution | Monochrome CMOS, 1280 × 720, 3.0 μm pixel size |
|---|---|
| Frame rate | 120 fps |
| Stabilization | Two-axis servo stabilization gimbal |
| Digital zoom | 4×; optical zoom not supported |
| AI processing | 6T computing power; detection time ≤50 ms |
| Tracking performance | Up to 120 fps with accuracy ≤2 pixels |
| Power | 12–28 V DC; average consumption ≤10 W |
| Weight and dimensions | ≤180 g; approximately Φ70 × 85 mm |
| Interfaces | 1-channel 100 Mbps Ethernet and 1-channel RS-TTL asynchronous UART at 230400 bps |
| Operating range | −30°C to +60°C; suitable for light to moderate rain |
Imaging and Stabilization
The DA0T1 uses a monochrome CMOS sensor to capture 1280×720 imagery at 120 fps. This frame rate provides a high temporal sampling rate for observing fast-moving subjects, while the 12 mm focal length and 18.2° horizontal by 10.3° vertical field of view define the optical coverage. Electronic zoom can extend the view by up to 4×, although the unit does not provide optical zoom.
Two-axis servo stabilization is intended to reduce the image movement caused by airborne platform motion. The documented working ranges are −30° to +30° in yaw and −50° to +50° in pitch. Picture-in-picture display and on-screen overlays can present camera, target, and platform information, but actual overlay content depends on the configured system output.
Onboard AI Detection
Integrated 6T edge computing supports onboard detection and recognition of people, vehicles, and drones. The documented AI detection time is no more than 50 ms, allowing the seeker to process visual targets without depending entirely on an external computing unit for every recognition task.
Tracking can operate at up to 120 frames per second with accuracy stated at no more than 2 pixels. These figures describe the product’s documented processing capabilities; they do not establish tracking performance in every scene. Target size, visibility, motion, weather, and camera configuration should be evaluated during mission-specific testing.
- Documented classes: people, vehicles, and drones
- AI detection time: ≤50 ms
- Tracking accuracy: ≤2 pixels
- Tracking rate: up to 120 fps
Airborne Tracking Applications
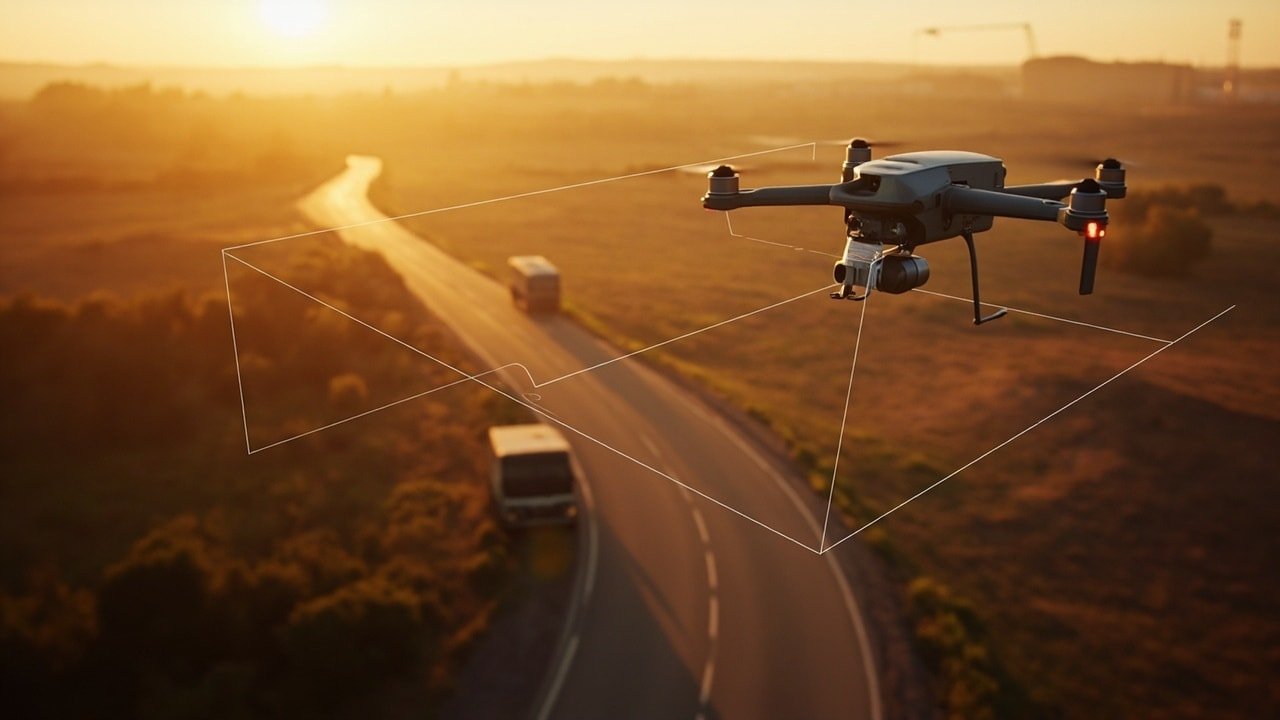
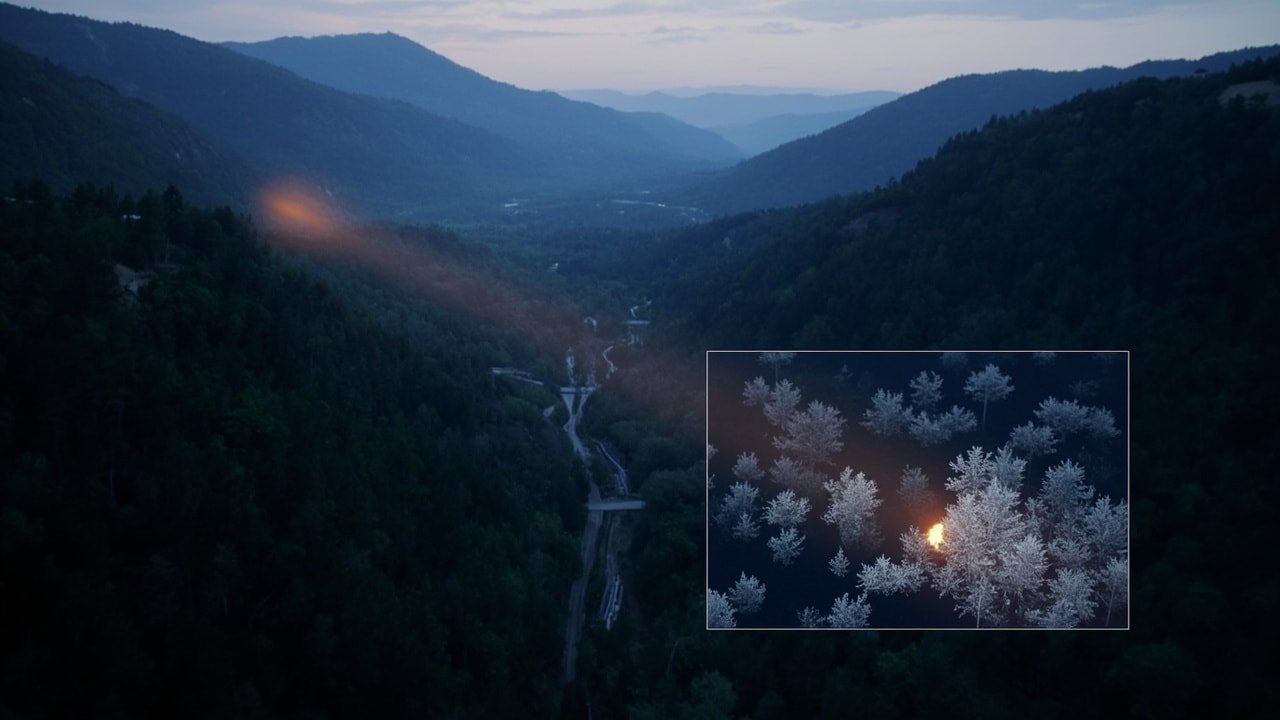
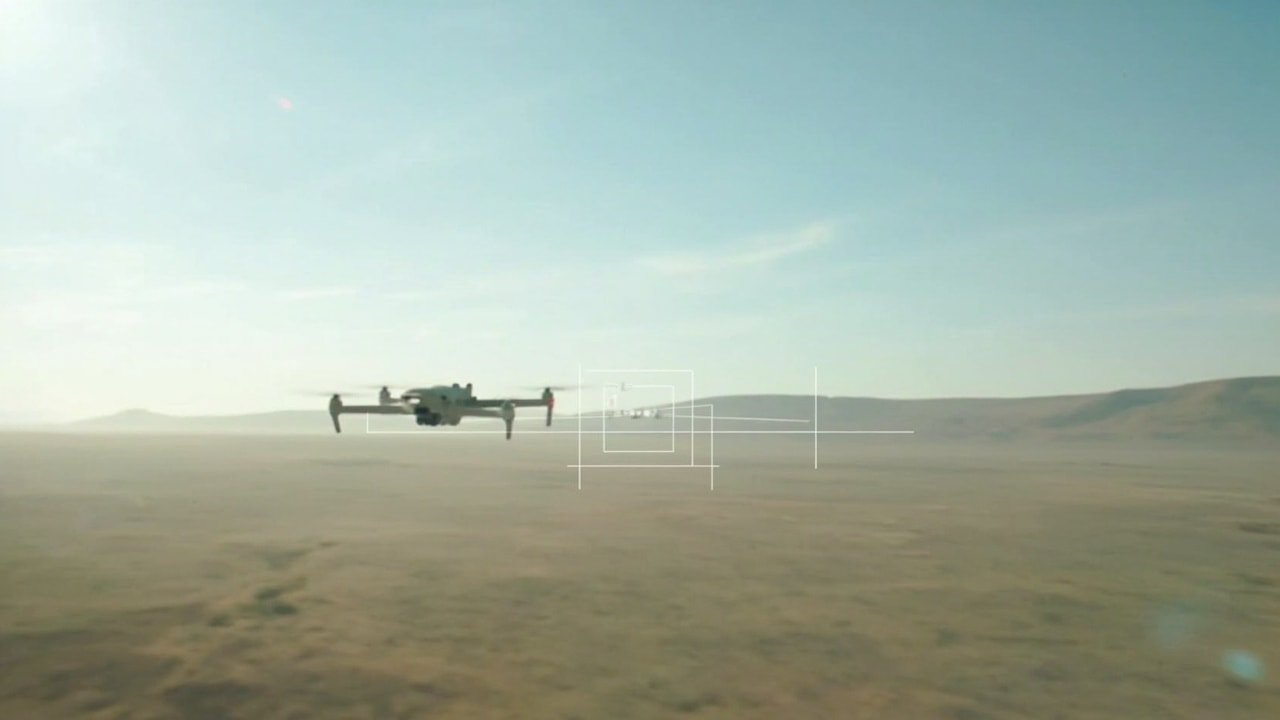
The combination of high-frame-rate imaging, rapid AI detection, stabilization, and a payload weight of no more than 180 g makes the DA0T1 relevant to interceptor UAVs and other high-speed airborne platforms. It can also support aerial surveillance, low-altitude drone observation, public-security patrol, law-enforcement monitoring, environmental inspection, and forest-fire visual monitoring.
Published drone-tracking distances depend on clear weather and visibility of at least 8 km. Under those stated conditions, the product tracks a 0.4×0.4 m drone at 320 m or more, a 1×1 m drone at 800 m or more, and a 2×2 m drone at 1500 m or more. These are source-specific conditions rather than guarantees for every environment.
Integration and Selection Checks
The DA0T1 requires 12–28 V DC and averages no more than 10 W. Integration planning should therefore include both the available input voltage and the platform’s power budget for the complete payload installation. The approximately Φ70 × 85 mm body and 180 g maximum weight are useful starting points for checking space and payload limits, but final mounting and clearance still require platform-specific verification.
Video output uses H.264 or H.265 encoding, while photographs use JPEG. A TF card up to 256 GB formatted as FAT32 provides local storage. The one-channel 100 Mbps Ethernet connection and RS-TTL asynchronous UART at 230400 bps offer options for data and control integration, but connector pinout, protocol details, and command compatibility should be confirmed before installation.
The unit operates from −30°C to +60°C and is stated to withstand shock of at least 200 g. It is also described as suitable for light to moderate rain. Those environmental claims do not imply waterproofing or unrestricted flight in severe weather, so platform enclosure, mission weather, and vibration conditions remain important selection checks.
- Confirm 12–28 V DC input and available payload power
- Check 100 Mbps Ethernet and RS-TTL interface requirements
- Validate connector, command, and video compatibility
- Review payload clearance, weather, and shock conditions
Frequently asked questions
What imaging and tracking rates does the DA0T1 provide?
The DA0T1 records 1280×720 monochrome imagery at 120 fps. Its onboard AI can track at up to 120 frames per second with documented accuracy of no more than 2 pixels, while the stated AI detection time is no more than 50 milliseconds.
Which targets can the onboard AI recognize?
The documented AI detection classes are people, vehicles, and drones. Recognition and tracking are performed through the integrated 6T edge computing module, reducing dependence on external computing for these supported target categories.
How much does the seeker weigh, and what power does it need?
The visible-light DA0T1 weighs no more than 180 g and measures approximately Φ70 × 85 mm. It accepts 12–28 V DC input and has an average power consumption of no more than 10 W, subject to integration checks with the intended aircraft.
Can the DA0T1 track small drones at long range?
Under clear weather with visibility of at least 8 km, published figures specify at least 320 m for a 0.4×0.4 m drone, 800 m for a 1×1 m drone, and 1500 m for a 2×2 m drone. Actual mission performance should be validated under relevant conditions.